Teach a real car to drive itself.
Drive the car in your browser. Train a policy on a cloud GPU and watch it learn. Race it. Then put it on the real car.
Drive the car now Race the trained policy Create an account
Hello Racer, the race and one vision lab need no account. The other labs and a GPU run need one: ask your instructor for an invite code. Want your own car? Buy a GOAT Racer at cryptide.com.
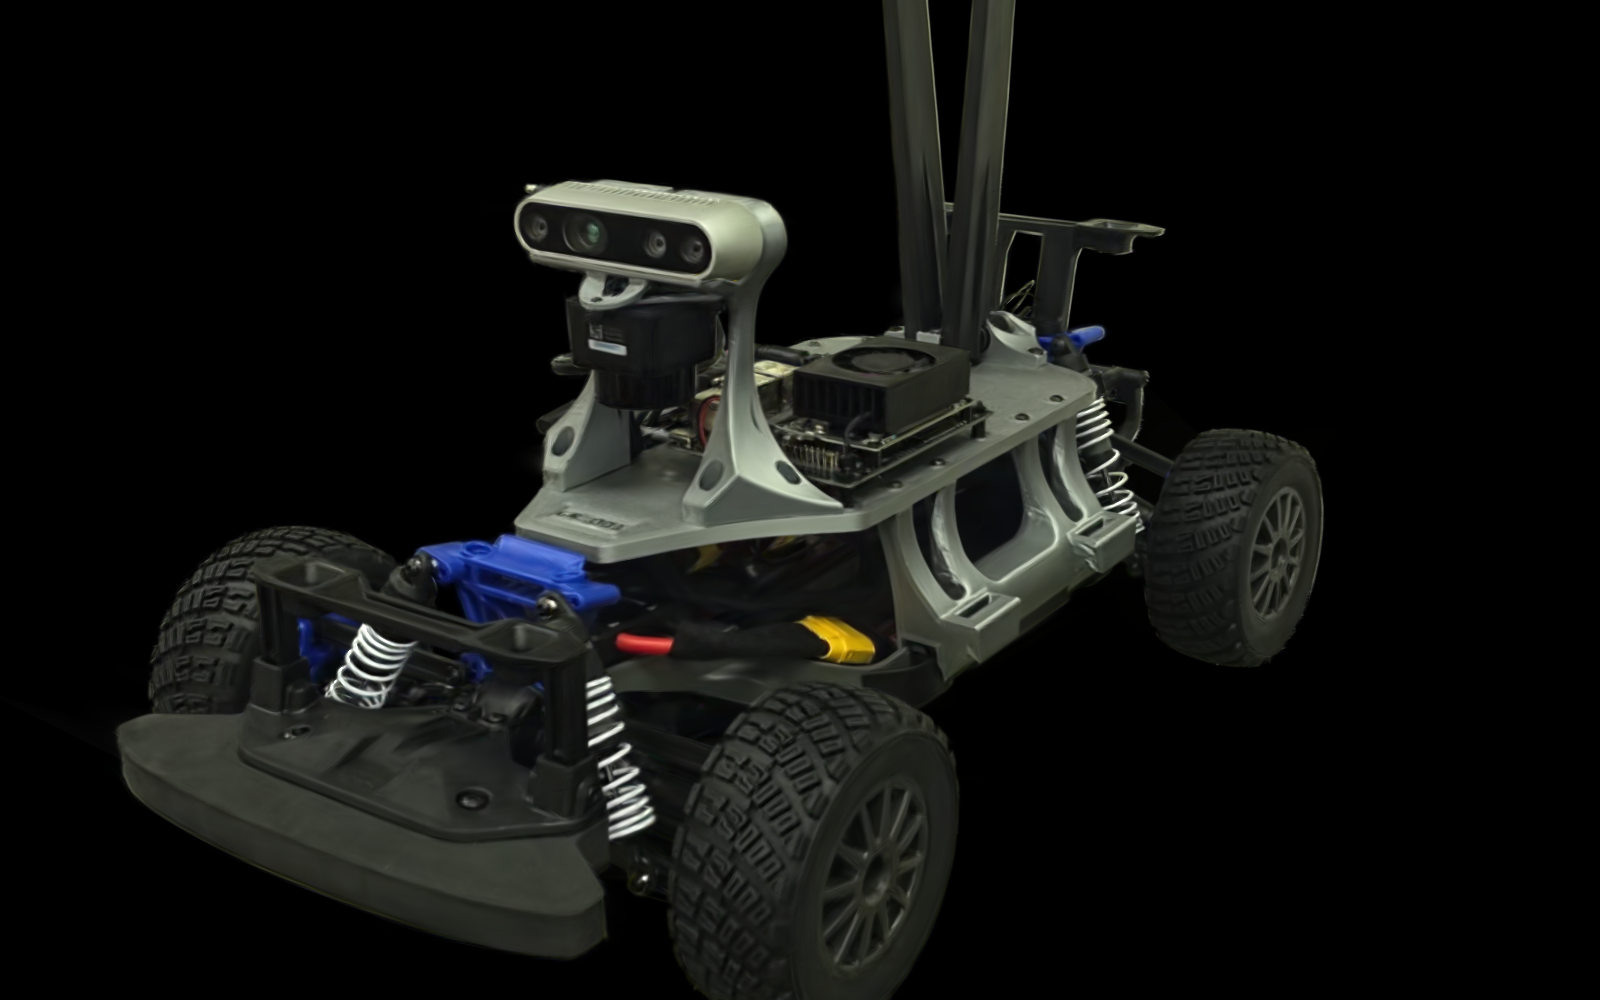


The same policy, in the sim and on the car
The simulator is a digital twin of the car. A policy you train in the cloud is the file the real car loads, with no change.
See the full loop on the NVIDIA livestream.
Nine labs, from your first drive to the real car
Start here
Meet the car, then the twin it is trained on.
Train
Hand the wheel over: train a policy and watch it drive.
See
A waypoint from a tag, then the open path from depth; then your code pulls the wheel while you drive.
Real car
Make a track, train the car's own policy on tracks like it, and prove the car can drive it.
Start free. Train on a cloud GPU when you are ready.
Free
0 USD
Hello Racer, The Twin, Seeing the Path, the First Training preview, and the race.
Start now →Training
64 USD a month
16 GPU hours of training each month for the training labs. Opens soon: create an account to be first.
Create an account →Your own car
from 2,700 USD
GOAT RACER 3, or GOAT RACER LEAN on pre-order. Battery, charger, and hard case in the box.
See the cars →No car? Send your policy to ours.
Train in the cloud, then run your policy on a real GOAT Racer in our lab. You get the video and the telemetry back. Tell me when it opens.
Before you start
Do I need a GPU?
No. Training runs on a cloud GPU. Your browser shows the live reward curve and the replay.
Do I need a car?
No. Every lab runs in your browser and on the cloud. The car is the last step, when you want your policy on real hardware.
What do I learn?
How a robot car senses and moves, its digital twin, reinforcement learning, how to read a training curve, vision from a depth camera, and how a policy goes from the simulator to the car.
Where are the docs?
At docs.goatracer.ai: getting started, the labs, and the car.
1. Drive
Hello Racer, in the browser. Steer and throttle: the two numbers every policy sends.
2. See
Depth, AprilTags, the open path: the camera labs run in your browser, on frames from the real car.
3. Train
Reinforcement learning on a cloud GPU. Live curve, replay, and the policy file.
4. Real car
Your policy goes to a GOAT Racer over the air, and its own software drives it. Get a car.