GOAT Racer

Teach a real car to drive itself.

Drive the car in your browser. Train a policy on a cloud GPU and watch it learn. Race it. Then put it on the real car.

Drive the car now Race the trained policy Create an account

Hello Racer, the race and one vision lab need no account. The other labs and a GPU run need one: ask your instructor for an invite code. Want your own car? Buy a GOAT Racer at cryptide.com.
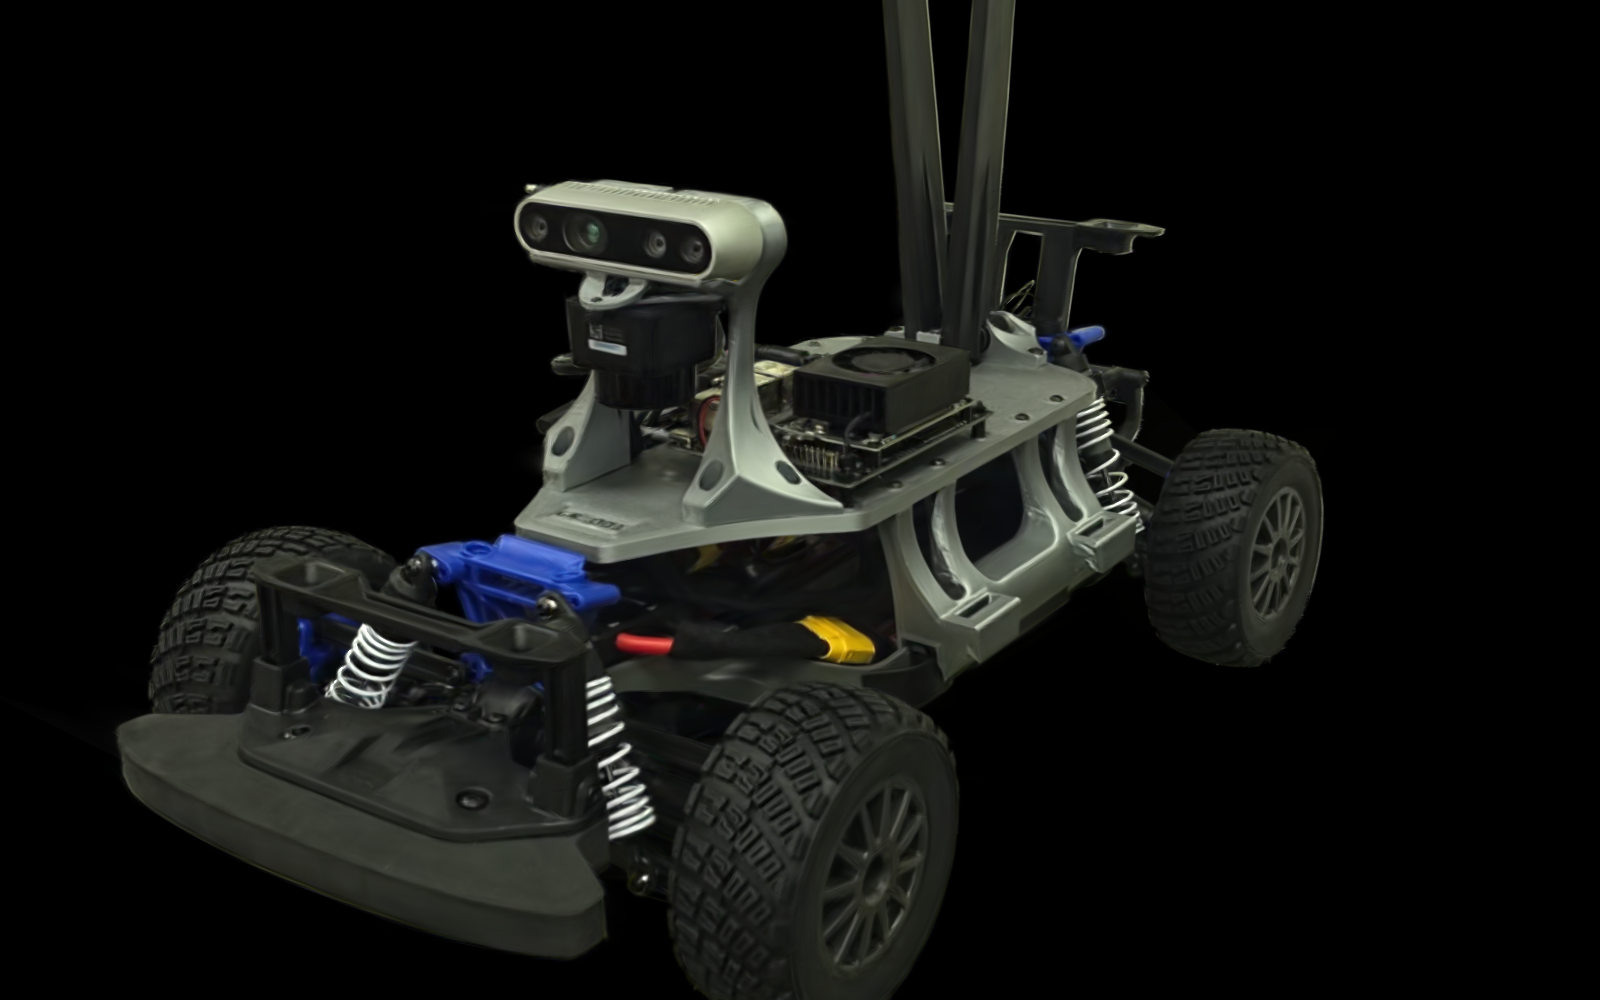
The GOAT Racer: a Traxxas rally chassis carrying a Jetson Orin, a depth camera and a lidar
The car A 1/10 rally chassis with a Jetson Orin, a depth camera and a lidar. The simulator is its digital twin, so the policy you train here is the policy it drives. Buy one at cryptide.com.
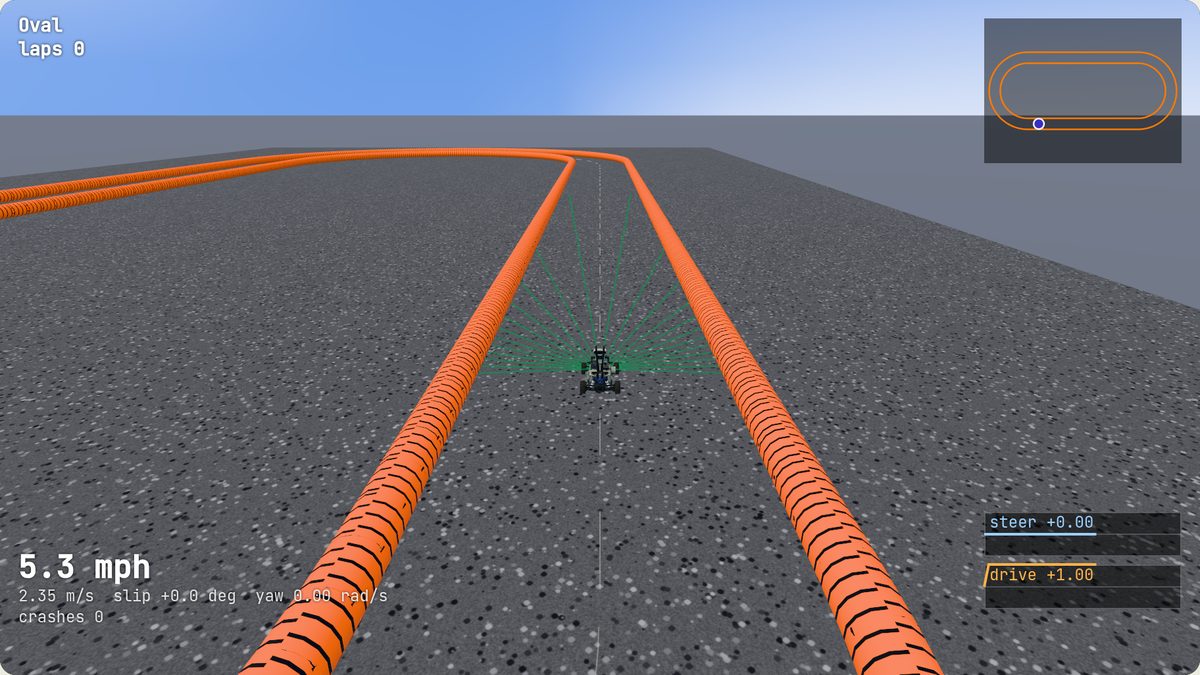
The simulated car on the oval track, with the 24 green lidar rays fanned out ahead of it
Drive Hello Racer: the car on the real track geometry, and the lidar rays the policy sees. Keys or a gamepad. No account.
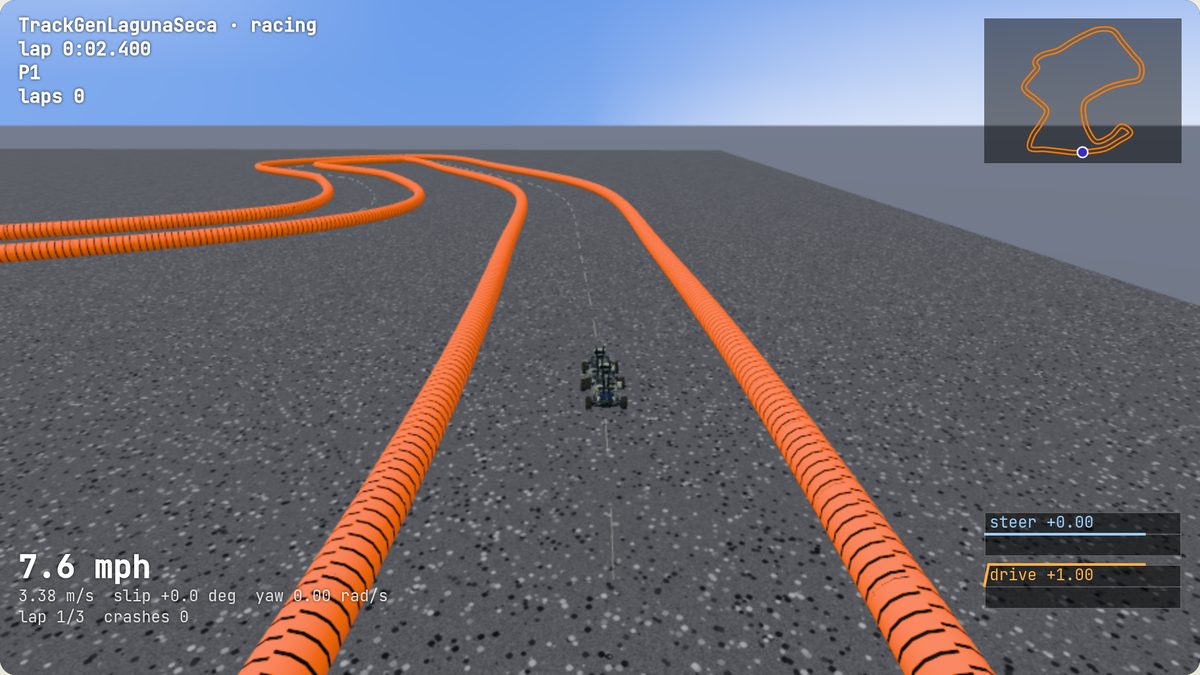
The race: the simulated car on the Laguna Seca track with the lap timer and a minimap
Race Race the trained policy in your browser. With an account your best lap goes on the board, checked by a re-run of your inputs on the server.
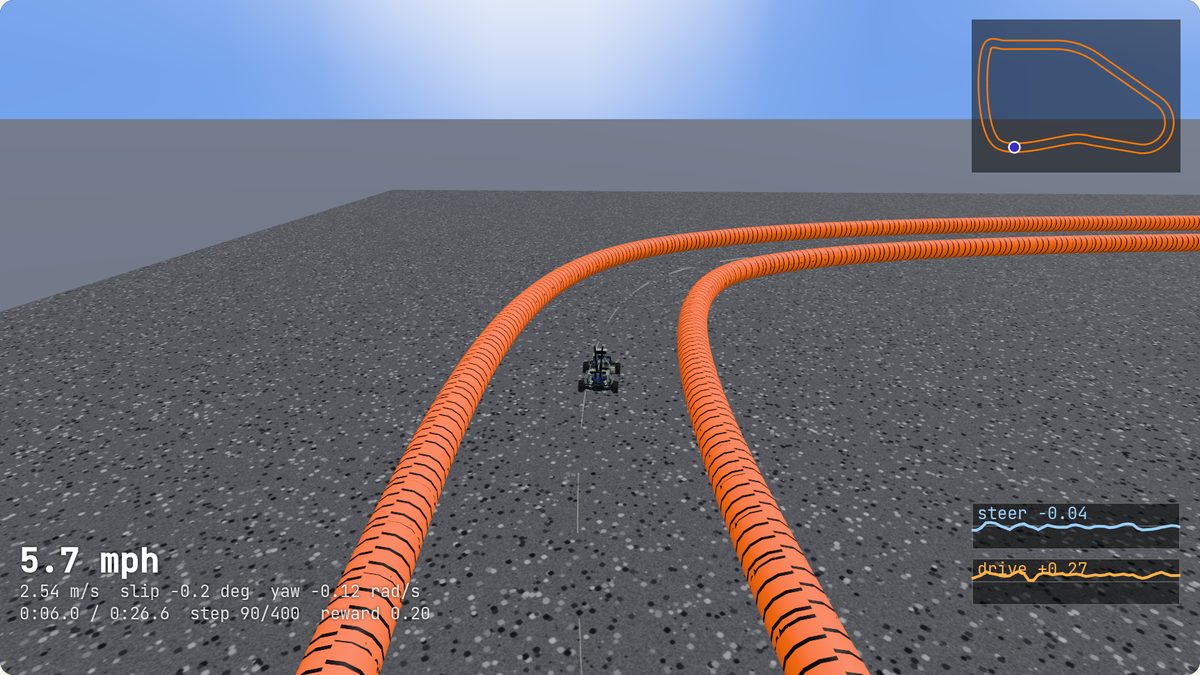
A replay of a trained policy driving between the orange track walls
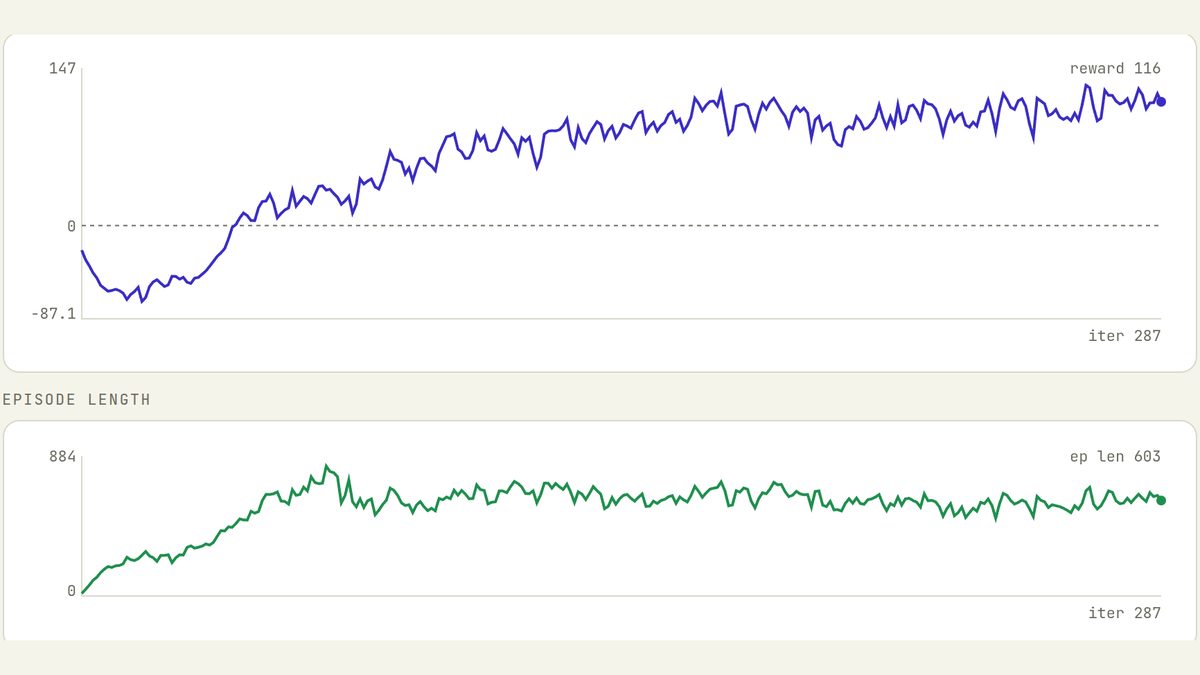
Train One click trains 1024 copies of the car on a cloud GPU. You watch the reward curve live. Minutes later you have a replay of your policy and the file the real car loads.
A reward curve from a training run, rising from below zero to a plateau
Learn to read it The second lab trains five times longer on purpose. The curve peaks and slides, and you learn to pick a policy by evidence, not by run length.

1. Drive

Hello Racer, in the browser. Steer and throttle: the two numbers every policy sends.

2. See

Depth, AprilTags, the open path: the camera labs run in your browser, on frames from the real car.

3. Train

Reinforcement learning on a cloud GPU. Live curve, replay, and the policy file.

4. Real car

Your policy goes to a GOAT Racer over the air, and its own software drives it. Get a car.